MX-HD Telescope
Features
Section titled “Features”The MX-HD driver provides the following functionality:
- USB serial connection
- Bluetooth RFCOMM serial connection when exposed by the operating system as a serial device
- Goto / Slew
- Sync
- Abort
- Park
- Unpark
- Driver-specific HOME action (
MXHD_HOME) - Standard INDI slew-rate selection
- Standard
TELESCOPE_TRACK_MODE- Sidereal
- Solar
- Lunar
- Timed pulse guiding
- INDI site / time synchronization
- HA-based
TELESCOPE_PIER_SIDEreporting for GEM operation
Connectivity
Section titled “Connectivity”The driver expects the mount to be presented by the operating system as a normal serial device.
Typical device names are:
/dev/ttyUSB0/dev/rfcomm0
The driver has been tested with:
- USB serial at
9600baud - Bluetooth RFCOMM serial presented by the OS as a serial device
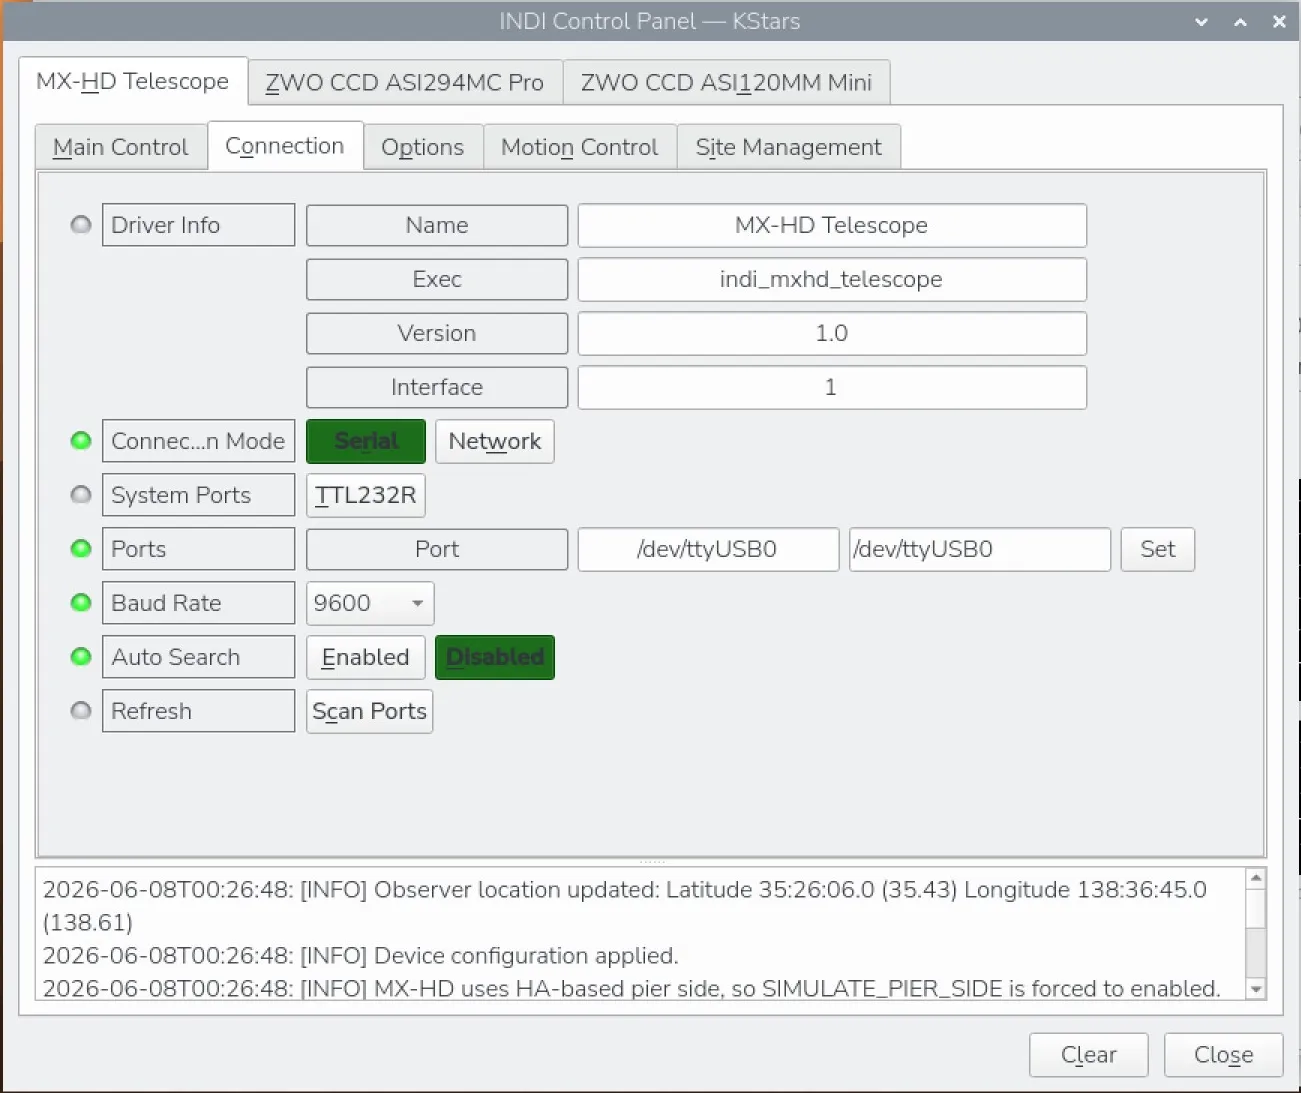
In KStars/Ekos:
- Select
MX-HD Telescopeas the mount driver. - Open the INDI Control Panel.
- In the Connection tab, set the serial port to the correct device.
- Set the baud rate to match the mount connection.
- Connect the mount.
Main Control
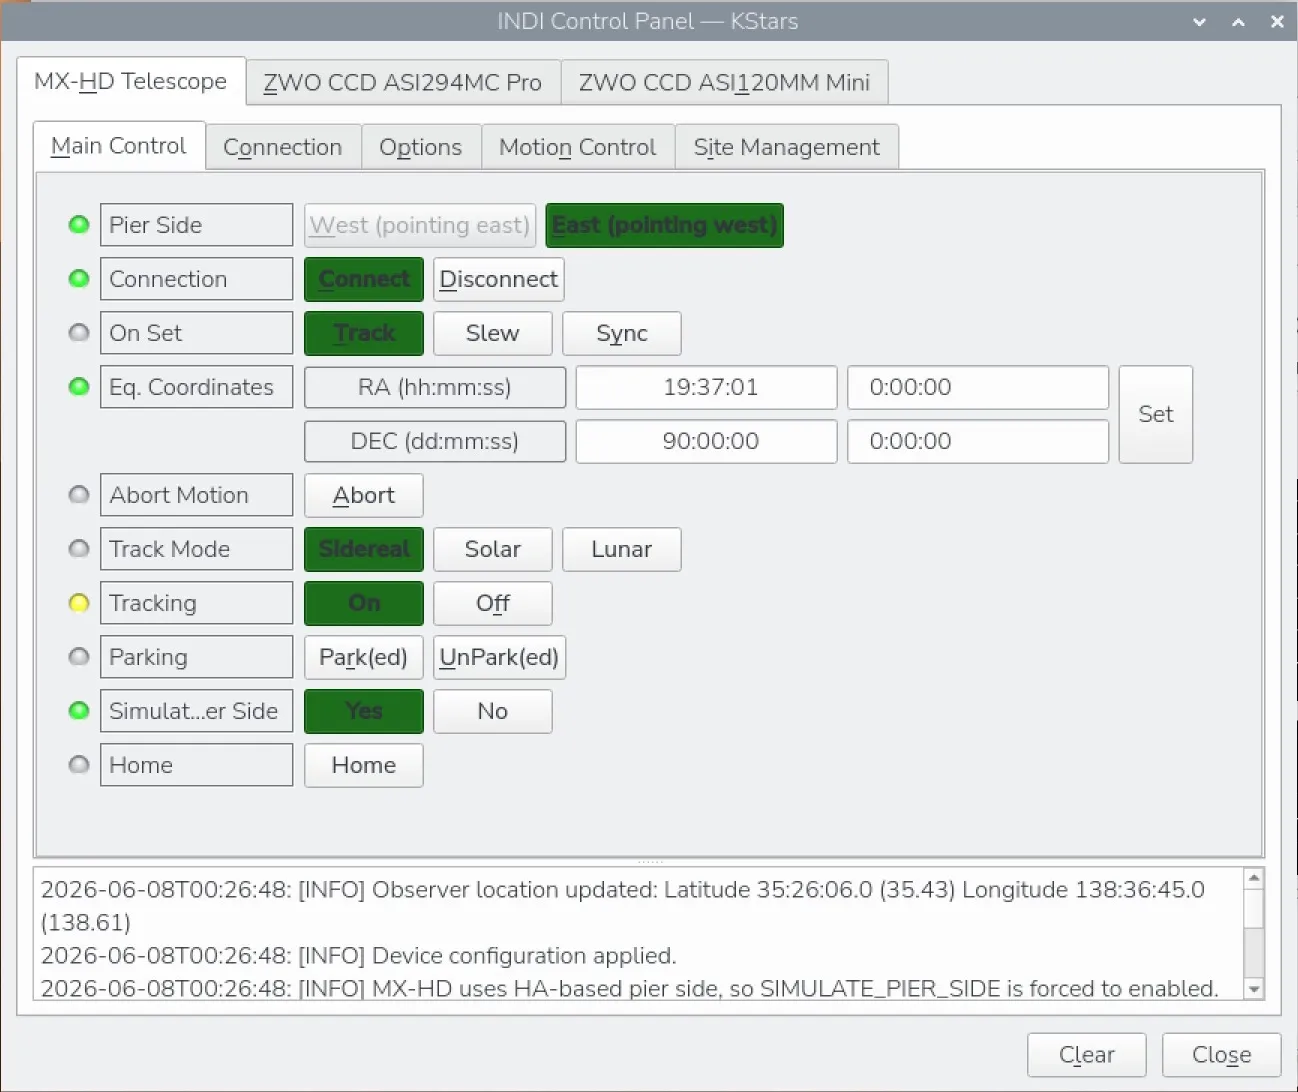
Section titled “Main Control”The main control area provides access to:
- current RA/Dec readout
- Goto
- Sync
- Abort
- Park / Unpark
MXHD_HOME
Important behavior:
MXHD_HOMEreturns the mount to its fixed HOME poseUnparkintentionally performs a HOME-return sequence before the driver clears the parked state
This behavior is specific to MX-HD and is used to restore a known mount attitude / position solution before remote operation resumes.
Tracking
Section titled “Tracking”The driver uses standard INDI TELESCOPE_TRACK_MODE and supports:
- Sidereal
- Solar
- Lunar
These are translated to the corresponding MX-HD commands internally.
Slew Rates
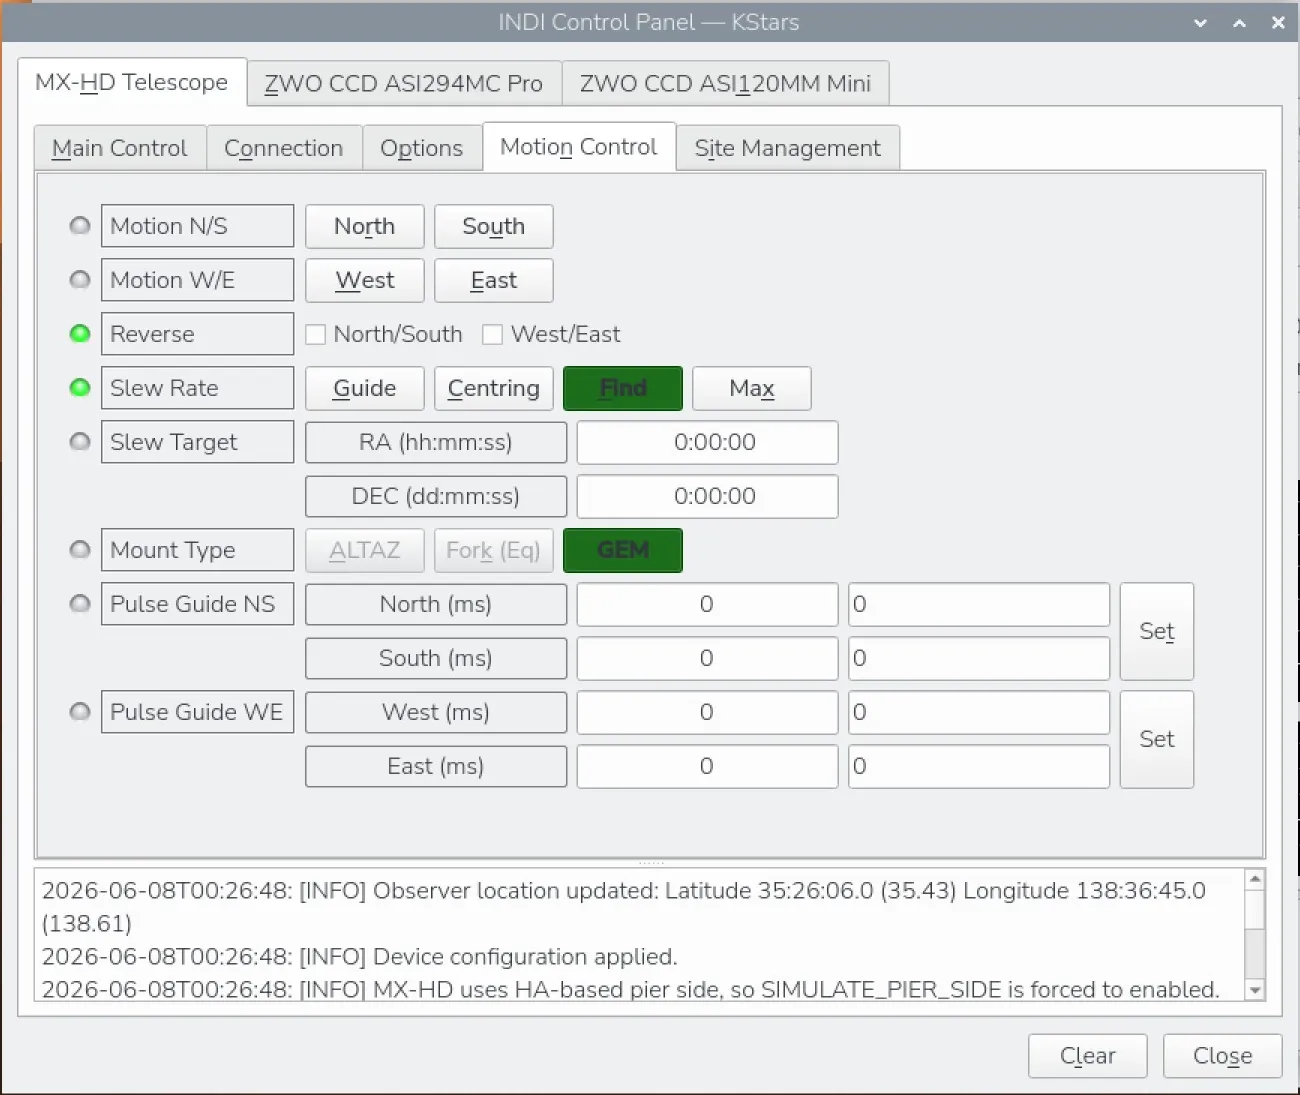
Section titled “Slew Rates”The driver supports the standard INDI slew-rate property with four rates:
- Guide
- Centering
- Find
- Max
These are mapped to the corresponding MX-HD rate commands and can be used by compatible INDI clients.
Site, Time, and Time Zone
Section titled “Site, Time, and Time Zone”The driver accepts TIME_UTC and GEOGRAPHIC_COORD from the INDI client and forwards them to the mount.
Important details:
- INDI longitude is interpreted as east-positive
- MX-HD receives longitude converted to its west-positive format
- INDI UTC offset is east-positive
- MX-HD receives the reversed-sign value required by its
:SGcommand - Local date and time sent with
:SCand:SLare derived from UTC plus the INDI-provided offset
The driver intentionally uses INDI-provided values and does not read the mount’s stored site values back into the control flow.
HOME and Unpark
Section titled “HOME and Unpark”The driver does not currently use standard TELESCOPE_HOME. Instead, HOME is exposed as a driver-specific MXHD_HOME action.
This was chosen because standard TELESCOPE_HOME handling caused client compatibility issues during testing.
MXHD_HOME returns the mount to its fixed HOME pose.
Unpark intentionally performs a HOME-return sequence before clearing the parked state. This is required by MX-HD to restore a known mount attitude / position solution before normal remote operation resumes.
Pier Side
Section titled “Pier Side”MX-HD does not report pier side directly.
The driver derives TELESCOPE_PIER_SIDE from hour angle using:
- the current UTC at each status update
- the current RA
- the INDI-provided east-positive longitude
SIMULATE_PIER_SIDE is enabled because pier side is inferred rather than reported directly by the mount.
Pulse Guiding
Section titled “Pulse Guiding”Timed pulse guiding is implemented and works with guider clients such as PHD2.
Supported guide directions:
- North
- South
- East
- West
Options
Section titled “Options”The driver follows the standard INDI POLLING_PERIOD property.
- Default polling period:
4000 ms
Status polling uses the MX-HD @ST# command.
- Bluetooth is supported only when the operating system exposes the connection as a standard serial RFCOMM device.
- During slews and HOME recovery, the driver avoids querying RA/Dec until the mount returns to a stable state in order to avoid transient serial timeouts.
Tested Configuration
Section titled “Tested Configuration”- Real MX-HD hardware
- Raspberry Pi 5
- libindi 2.2.1
- KStars/Ekos
- USB serial (
/dev/ttyUSB0) - Bluetooth RFCOMM serial (
/dev/rfcomm0)