ScopeLink
ScopeLink
Section titled “ScopeLink”Installation
Section titled “Installation”| Driver name | ScopeLink |
| Executable | indi_scopelink |
| Author | Bence Toth, Astrolabs Hungary Kft. |
| Maintainer | Bence Toth <[email protected]> |
| Version | 1.1 |
| Device type | Focuser, rotator, dust cap, light box, auxiliary |
| Connection | Serial (USB CDC-ACM) |
| Minimum INDI | 2.0.0 |
| Platforms | Linux (amd64, arm64) |
Install with sudo apt install indi-scopelink, or build it from source — the driver lives in
indi-3rdparty, and its INSTALL.md has the instructions.
After installing, reload the udev rules so the controller is reachable without root privileges:
sudo udevadm control --reload-rules && sudo udevadm triggerOverview
Section titled “Overview”ScopeLink is a single-box telescope controller from Astrolabs. One USB connection drives:
- a stepper focuser
- a field rotator
- a motorised front flap over the telescope aperture, in up to three separately driven parts
- a flat panel
- two mirror cooling fans, thermostatically controlled against the mirror-to-ambient temperature difference or switched by hand
- two auxiliary power outputs
- a powered USB hub — two ports with per-port fault reporting on generation 3, six ports on generation 4
The driver publishes all of it as one INDI device. The interfaces it claims depend on what the connected controller actually has, which is read out of the hardware at connect time.
It also reads and writes the controller’s configuration, its fault store and its motor calibration, and can replace its firmware — all over the same USB connection, with nothing else installed.
Supported models
Section titled “Supported models”| Generation | Motors | Front flap | Aux power | USB hub | Smart switch diagnostics |
|---|---|---|---|---|---|
| 2 | 2 | yes | yes | no | no |
| 3 | 2 | yes | yes | 2 ports | yes |
| 4 | 3 | yes | yes | 6 ports | yes |
A rotator needs two things: firmware that knows what a rotator is, which means interface 1.1, and a motor of its own to be assigned to. In practice that is a three motor controller, or a two motor one with no front flap fitted.
Generation 3 is the production hardware. Generation 2 is the earlier controller; it runs the same code path, differing only in what the capability read at connect time turns on. The driver is tested against real units of both.
Generation 4 is supported but has not been tested against hardware, because none exists yet. It is checked against the simulator, which serves the same frames from the same capability set the driver decodes with.
Which motor drives what
Section titled “Which motor drives what”Up to interface 1.0 the motors were wired to their jobs: motor 1 focused and motor 2, where there was one, opened the flap. From interface 1.1 — which is generation 4, and generation 3 units reflashed with that firmware — the controller holds the mapping as a setting instead, and the driver reads it when it connects. Everything follows from it:
- The devices offered. A controller with no motor assigned to the rotator publishes no rotator, and the same goes for the focuser and the front flap. The assignment is named in the log on every connect.
- Which travel belongs to which device. The focuser’s calibrated end of travel is motor 1’s on one controller and motor 3’s on another; the driver reads the one the assignment points at.
- How the flap is driven. The controller is asked to open the flap rather than to move a motor, so a flap split into two or three parts is opened in the configured order with the configured delays between the parts — sequencing that runs in the controller, where nothing can be unplugged half way through it. A Flap state property shows what the controller reports about the flap as a whole, which is not the same question as where one of its motors is standing: a part waiting out its delay is still opening.
The assignment is on the Parameters tab, under Focuser, Rotator and Front flap. The settings offered are the motors your controller actually has, and the rules are the controller’s own — nothing may name a motor that is not fitted, the flap parts have to be a run without a gap in it, and no motor may be claimed by two functions. An assignment that breaks one of them is refused by the controller; if a controller is somehow holding one anyway, the driver says what is wrong with it and offers no focuser, rotator or flap until it is corrected.
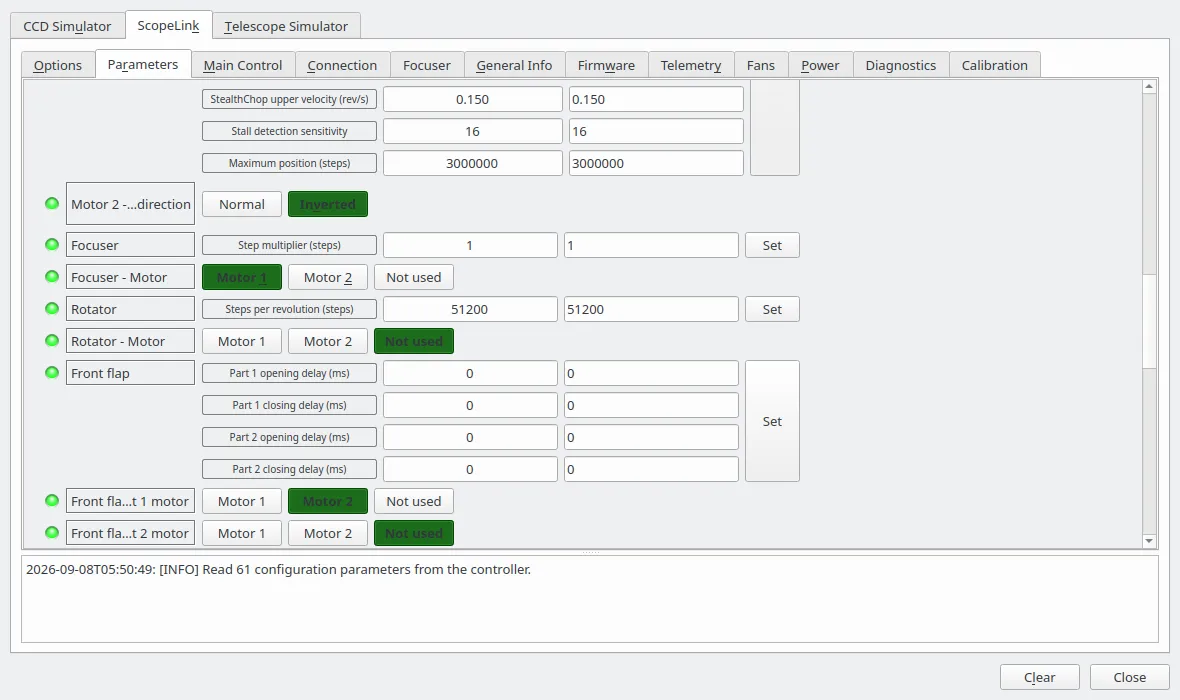
A change needs the controller restarted, not just reconnected. The controller reads its configuration when it starts and drives from that copy, so an assignment written while it is running is stored but not acted on: it goes on driving the one it started with, and refuses a command for anything the new assignment adds. The driver says as much in the log when you change one.
Restart controller, at the bottom of the Parameters tab, is what does it. The controller restarts, the link drops while it leaves the USB bus and comes back — a few seconds — and the driver then connects again by itself, which is when it decides which devices to offer. Pulling the power does the same thing; so does a firmware update, which ends with a restart for exactly this reason. If the controller does not come back within thirty seconds the driver says so and stops waiting; unplug it and plug it back in, then connect again.
The infrared temperature sensor is a fitting option rather than a generation difference. On a unit without one, the temperature readings, the mirror ΔT and the automatic fan targets are not offered at all, rather than being offered and failing.
Connecting
Section titled “Connecting”Select ScopeLink in the Focuser slot of your Ekos equipment profile. Ekos picks up the dust cap and light box interfaces from the same device automatically once it connects, so the front flap appears in the cap controls and the flat panel in the flat frame settings — there is no need to add the device twice.
On the Connection tab, set the port. Anything but /dev/ttyACMn, which is renumbered whenever
another CDC device is plugged in first. With one controller, use the name the udev rule gives it:
ls -l /dev/scopelink# /dev/scopelink -> ttyACM0With more than one, use the per-unit name under /dev/serial/by-id/, since both claim /dev/scopelink
and one of them wins:
ls -l /dev/serial/by-id/# usb-Astrolabs_ScopeLink_206135713630-if00 -> ../../ttyACM0The number in that name is the controller’s USB serial, so it identifies one physical unit and a saved
profile keeps working across reboots and however many other USB devices are plugged in. Without the udev
rule installed you also have to be in the dialout group to open the port.
NOTE
A controller flashed before the identifiers were assigned has neither of those names. ScopeLink
reported ST’s generic USB identifiers, 0483:5740, until Astrolabs was assigned 0483:a5d3 and
0483:a5d4 of its own, and every
STM32 device running the stock USB CDC stack reports the generic pair too. The udev rule grants such a
unit access and deliberately gives it no /dev/scopelink, because it could not tell it from any other
such device. Its by-id name is
usb-STMicroelectronics_STM32_Virtual_ComPort_in_FS_Mode_<serial>-if00, and everything else about the
driver is the same.
The baud rate is offered because libindi’s serial plugin expects one, but the controller is a CDC-ACM device and ignores it.
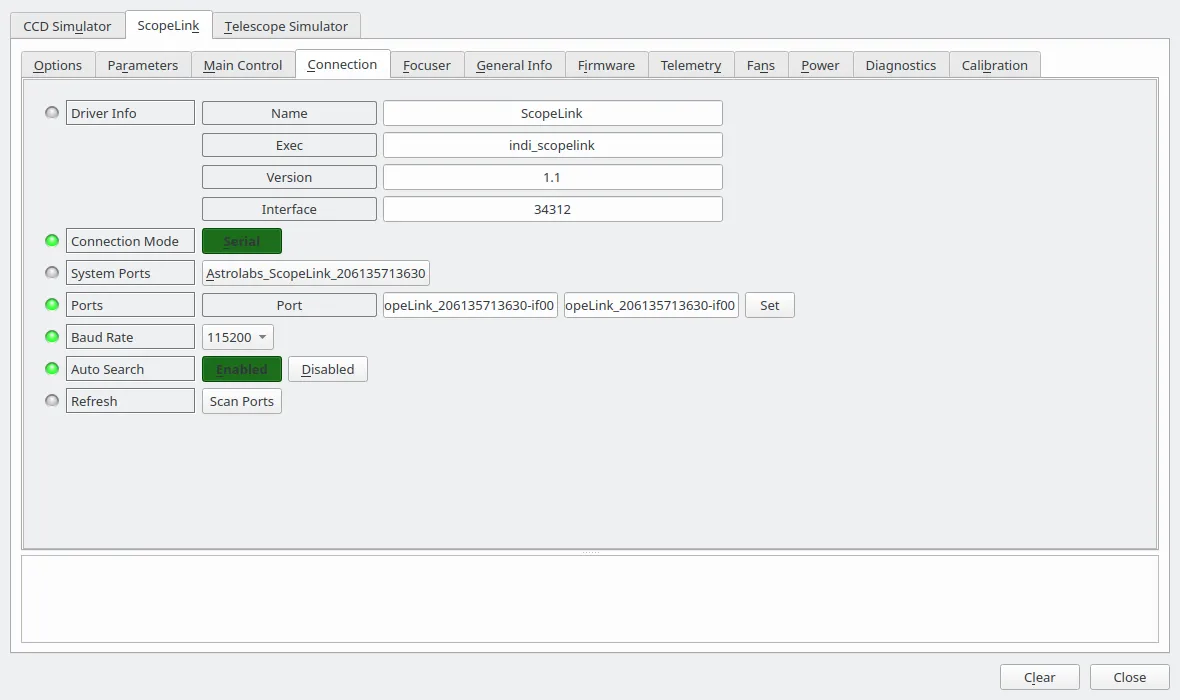
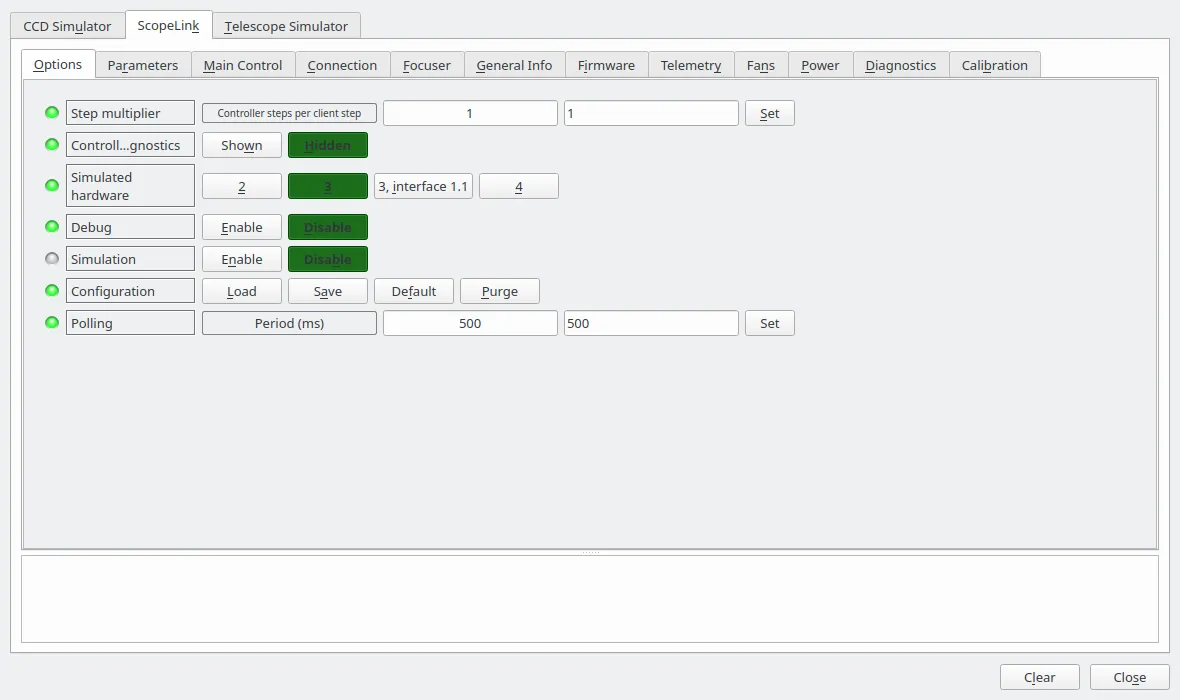
Two options are worth setting before the first connection, on the Options tab:
- Step multiplier — how many controller steps make one client step. Leave it at 1 unless the focuser’s travel is large enough that a client is unhappy with the numbers. It is applied when the driver connects, so changing it while connected has no effect until you reconnect. On a controller from interface 1.1 the multiplier is held in the controller instead and this setting is ignored; see the Focuser tab below.
- Controller diagnostics — off by default. Turning it on adds the controller’s own die temperature, supply rail, CPU and stack load and I²C error counter to the Telemetry tab. These are for fault-finding, not for observing.
- Simulated hardware — which controller the driver imitates while Simulation is on. Ignored otherwise. Four entries for three generations, because a generation is not a frame layout: the same generation 3 board runs interface 1.0 and 1.1, and 1.1 is a different layout rather than a different board. Generation 4 exists only on 1.1 and so needs no second entry. See “Running without a controller” below.
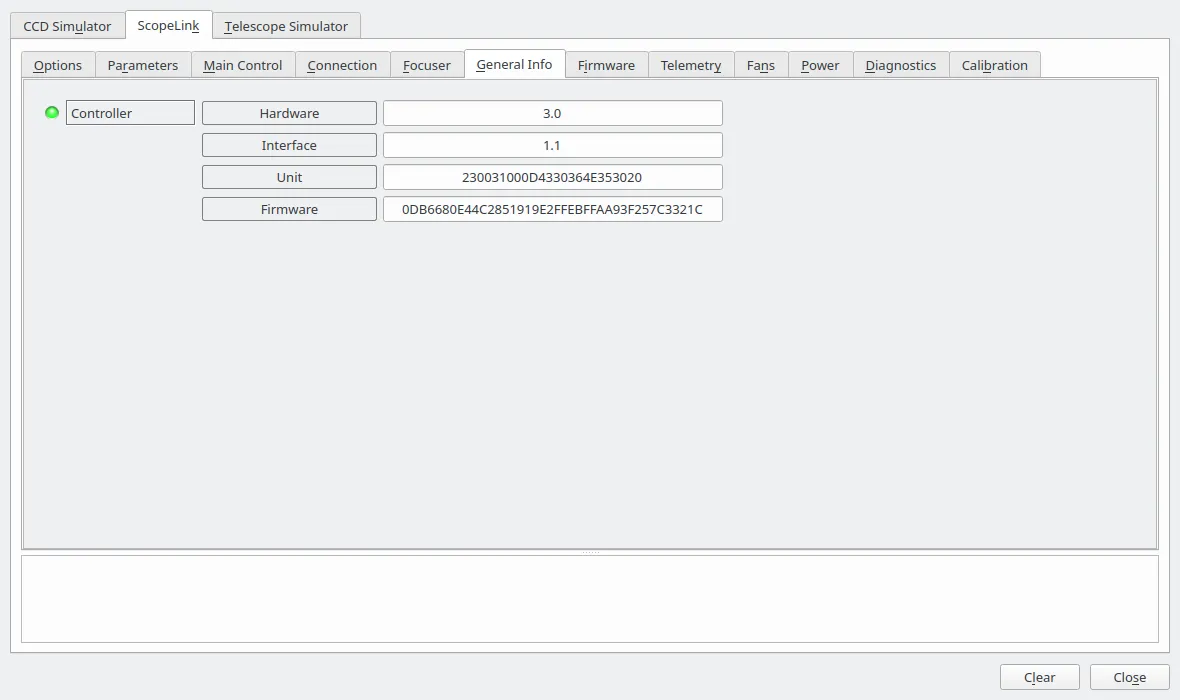
On a successful connection the General Info tab shows the hardware and interface versions, the unit’s hardware identifier and the firmware string. Quote all four in any support request.
Running without a controller
Section titled “Running without a controller”Turn Simulation on before connecting and the driver answers itself: no port is opened, and every tab below behaves as it does on hardware, including motion, the flat panel, the fault store and the configuration parameters. Simulated hardware on the Options tab picks which controller it imitates, which is what makes the differences between them visible — the USB hub and the smart switch settings appear and disappear as they would on the real controllers, and the interface 1.1 entry sends the frame layout that firmware uses.
It is meant for trying the driver out, for reproducing a problem without the hardware to hand, and for client development. The simulated controller is answerable and self consistent; it is not a model of the firmware, and the values it reports are plausible rather than measured.
The same simulated controller is also available on a pseudo terminal, from the scopelink-simulator
command, for anything that needs a port rather than a driver.
Focuser
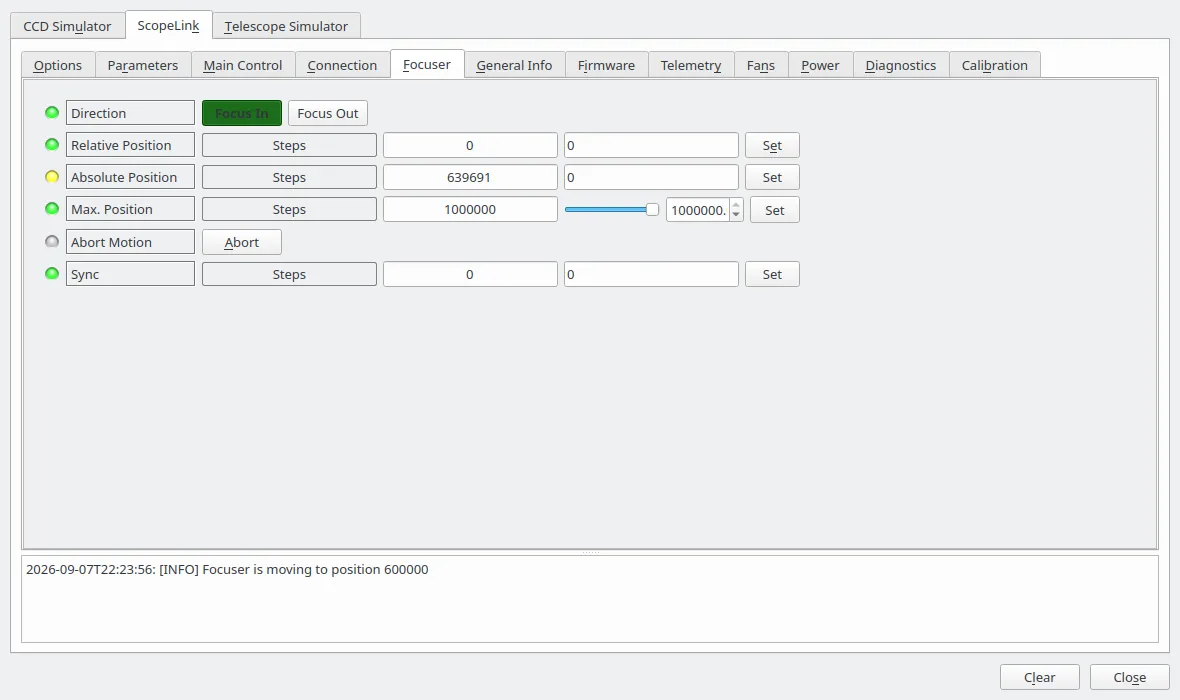
Section titled “Focuser”Standard INDI focuser controls: absolute position, relative moves, abort, and sync.
The travel limit is read from the controller’s own calibration when the driver connects, and
FOCUS_MAX is deliberately read-only — writing it from the focus module would silently overwrite a
bench calibration. Recalibrating is what the Calibration tab is for.
Step multiplier is how many motor steps make one step as a client sees them. On a controller from interface 1.1 onwards it is held in the controller rather than in the driver, so this driver and the vendor’s Windows one read the same number and a step means the same thing on either — set it on the Parameters tab, under Focuser. On earlier controllers it is the driver setting on the Options tab, applied when the driver connects.
Temperature shows the ambient reading from the infrared sensor, and is what Ekos uses for temperature-compensated focusing. If the sensor stops answering, the property goes to alert rather than reporting the plausible-looking -273 °C the hardware sends in that case.
If a move ends with the motor stopped somewhere other than the commanded position, the driver reports an alert rather than a completed move. That normally means the focuser is obstructed or the motor’s stall detection sensitivity is set too high.
Rotator
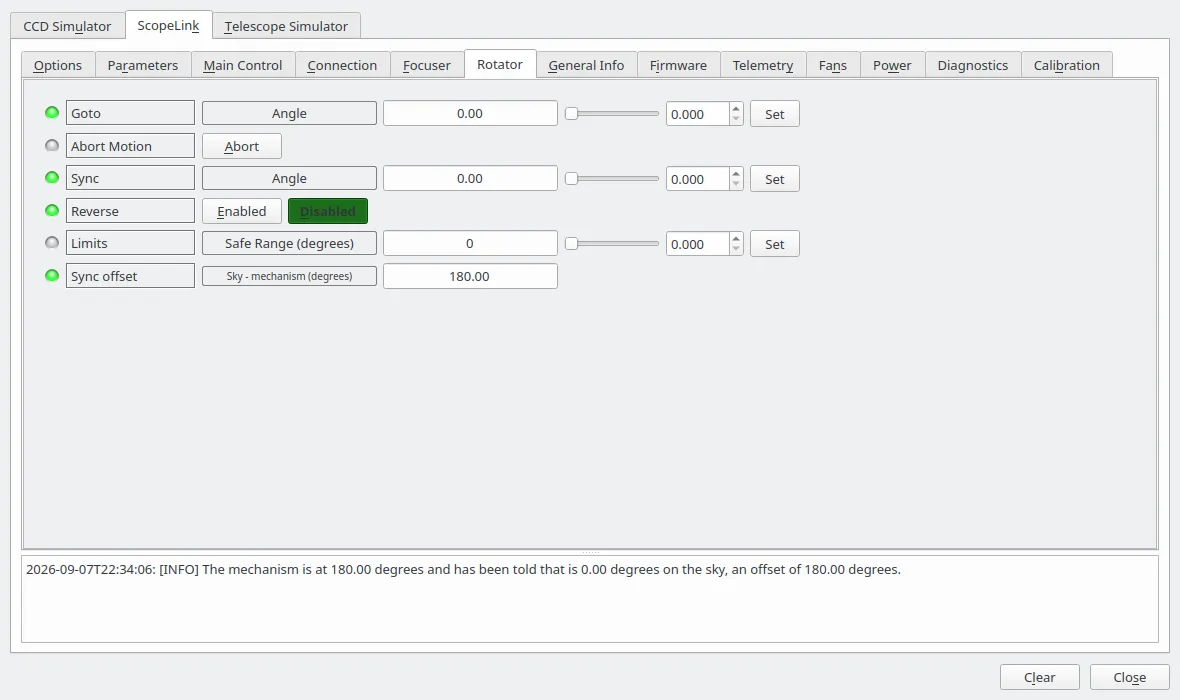
Section titled “Rotator”Offered on a controller that has a motor assigned to the rotator, and only once that motor has a calibrated travel — every angle is turned into a step count against it, so an uncalibrated rotator is not published at all. Calibrate it on the Calibration tab and reconnect.
Goto rotates to a position angle in degrees. How far the mechanism can actually turn is whatever it was calibrated to: less than a full turn on a rotator limited by its cabling, and more than one on a rotator that is not. An angle the travel does not reach is refused rather than approximated to the nearest end stop, which would leave a client believing it had rotated the camera when it had not. Where the travel reaches an angle more than once, the driver drives to the reachable step count nearest to where the mechanism already is — the shortest move, and the one that does not unwind a cable it has just wound up.
Sync tells the driver that the mechanism is where it is and the sky is somewhere else than it thought. Nothing is sent to the controller and nothing moves: what changes is the offset between the mechanism and the sky, shown as Sync offset and saved with the configuration, so a sky calibration outlasts the connection.
Reverse runs the angle the other way against the mechanism. It does not re-measure the sync offset, which was taken with the angle running the other way — sync again after reversing.
Abort motion stops the rotator where it is. The position it stops at is a real position like any other, so nothing needs re-establishing afterwards, unlike a flap stopped mid-travel.
Safe range is the standard INDI rotator limit, and this driver does not use it: what a rotator can reach is decided by its calibrated travel, which is measured rather than typed in. Leave it at 0.
Front flap (dust cap)
Section titled “Front flap (dust cap)”The flap is published as a dust cap, so Ekos opens and closes it as part of a sequence without being asked each time.
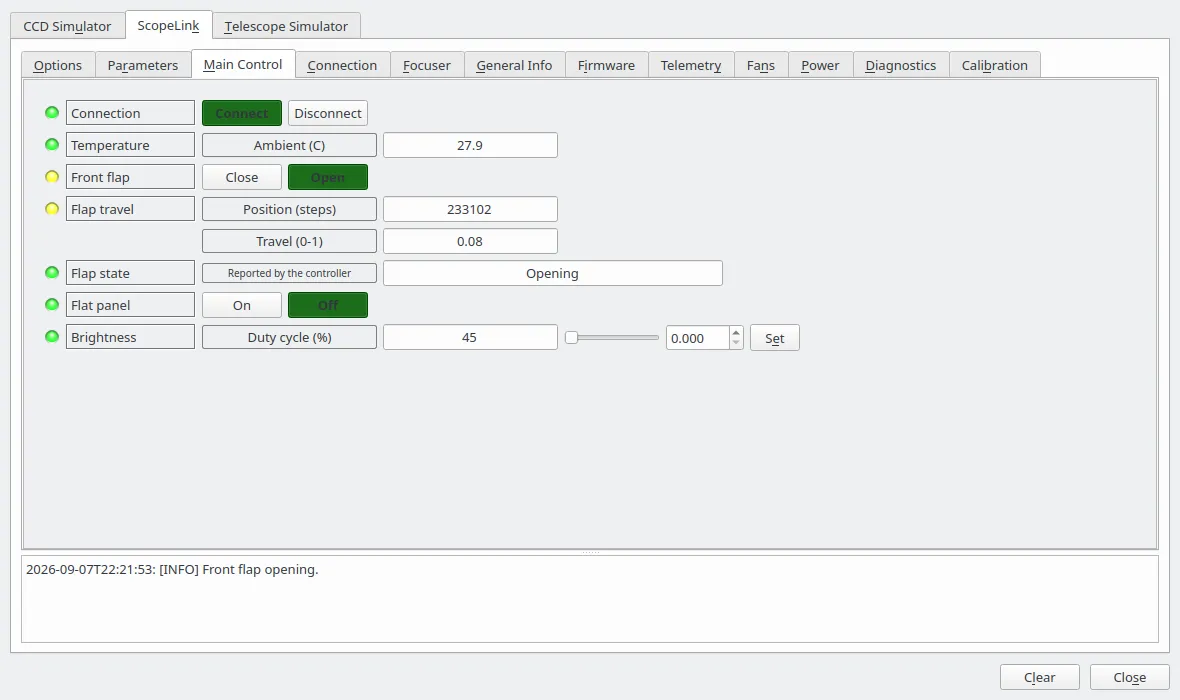
Park closes the flap, Unpark opens it. The raw motor position and the fraction of travel are shown alongside, which is useful while calibrating; on a flap of several parts they are the first part’s, and Flap state is what describes the flap as a whole.
If the driver connects and finds the flap stopped somewhere between its end stops — after a power cut mid-travel, for instance — it reports the state as unknown and does not move it. Close or open it once to re-establish where it is.
A flap made of more than one part needs every part calibrated before it is offered as a dust cap: a flap with one calibrated half cannot be opened any more than one with none can.
Flat panel (light box)
Section titled “Flat panel (light box)”Flat panel switches the panel on and off; Brightness sets the duty cycle from 0 to 100 %. Ekos drives both automatically when taking flat frames: a flat job closes the cover, turns the panel on, takes its frames and turns it off again, without being asked.
The brightness you set while the panel is off is remembered and applied when you switch it on. Switching the panel on with the brightness at zero produces no light, and the driver says so in the log.
Telemetry
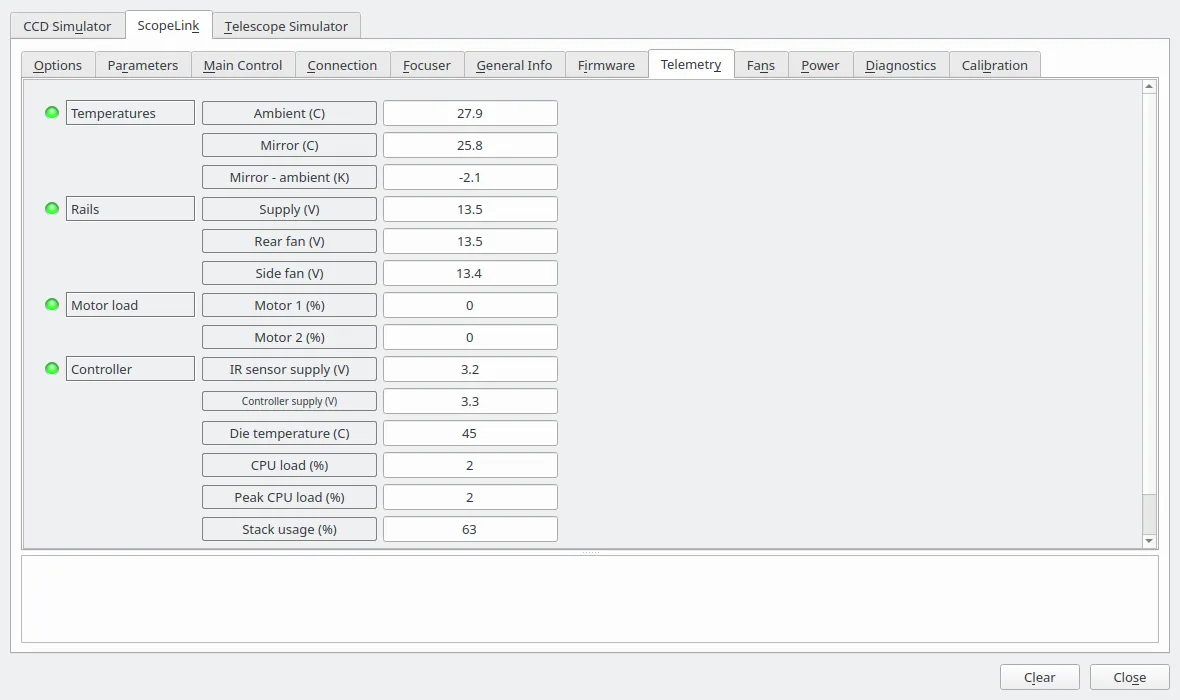
Section titled “Telemetry”Read-only. Supply, rear fan and side fan rail voltages; ambient and mirror temperature and the difference between them; and the load on each motor.
With Controller diagnostics enabled in Options, a second group appears with the infrared sensor supply, the controller’s own supply and die temperature, CPU and peak CPU load, stack usage and the I²C error counter.
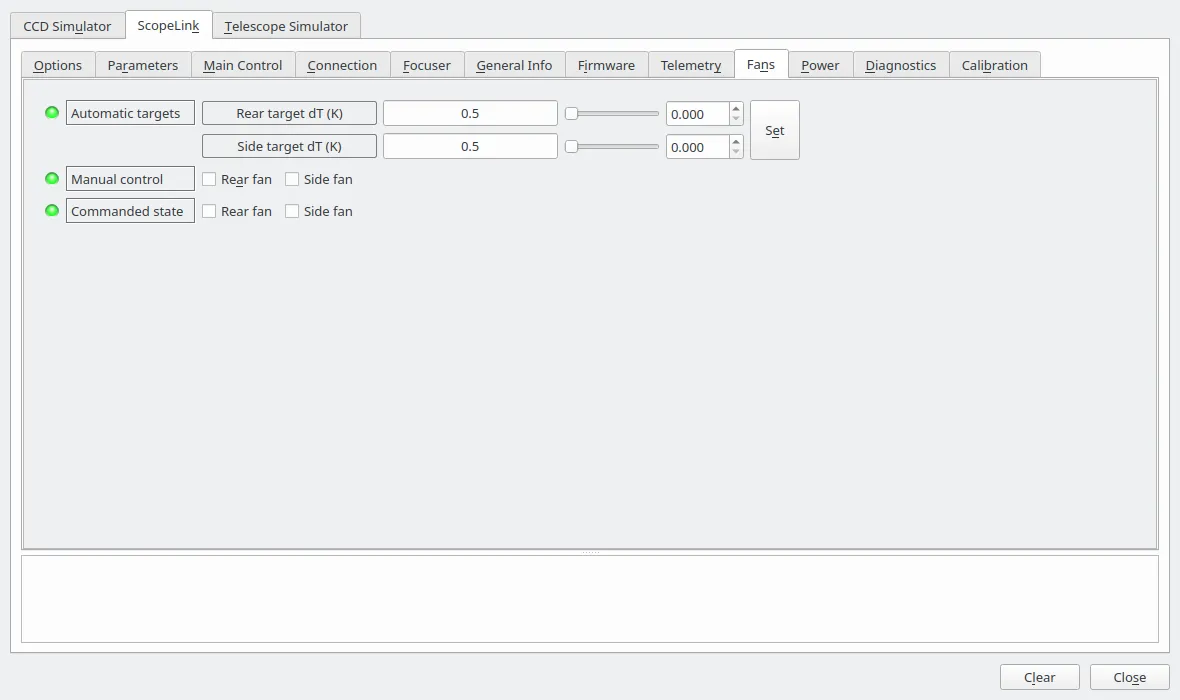
Each fan can be left under the controller’s own thermostat or taken over manually.
- Manual control — enables the override for each fan independently.
- Commanded state — what each fan does while its override is enabled.
- Automatic targets — the mirror-to-ambient temperature difference each fan aims at when it is not overridden, in Kelvin. Only offered on a unit with the temperature sensor fitted, since there is nothing to regulate against without it.
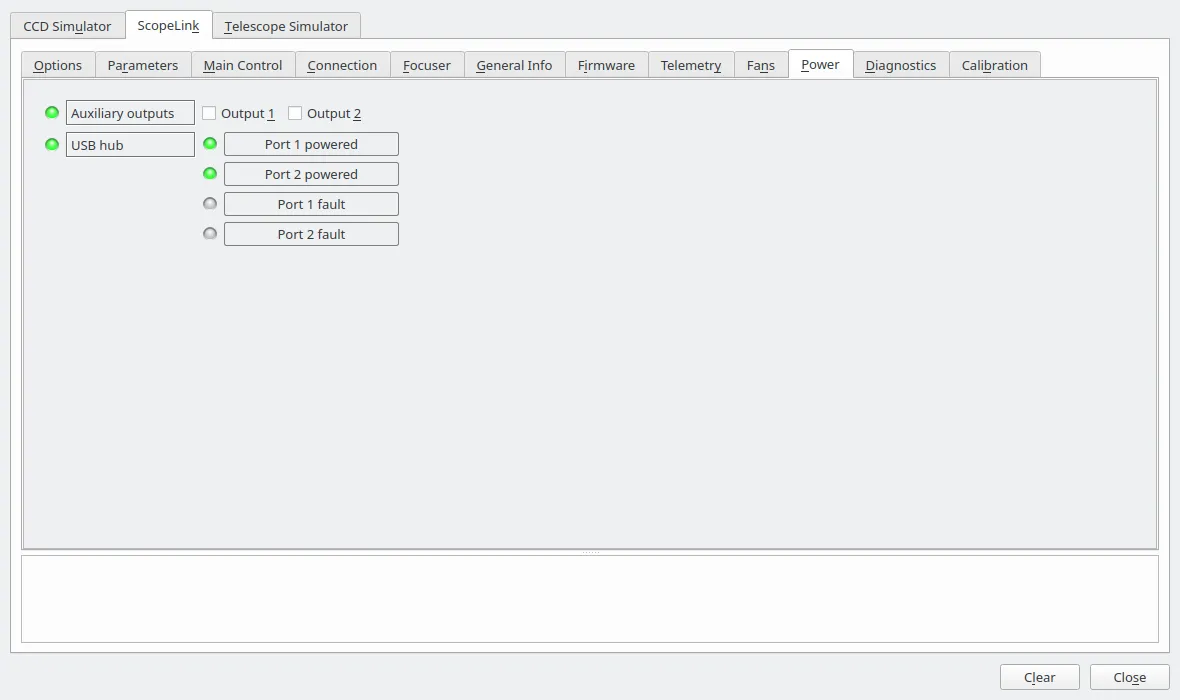
Auxiliary outputs switches the two auxiliary power outputs.
USB hub reports the downstream ports: whether each is powered, and — on generation 3 — whether it has tripped. A port fault lights red and is also recorded in the fault store. A generation 4 hub has six ports and no separate fault lamps: it reports a tripped port by dropping that port’s power, which the lamp beside it already says.
Parameters
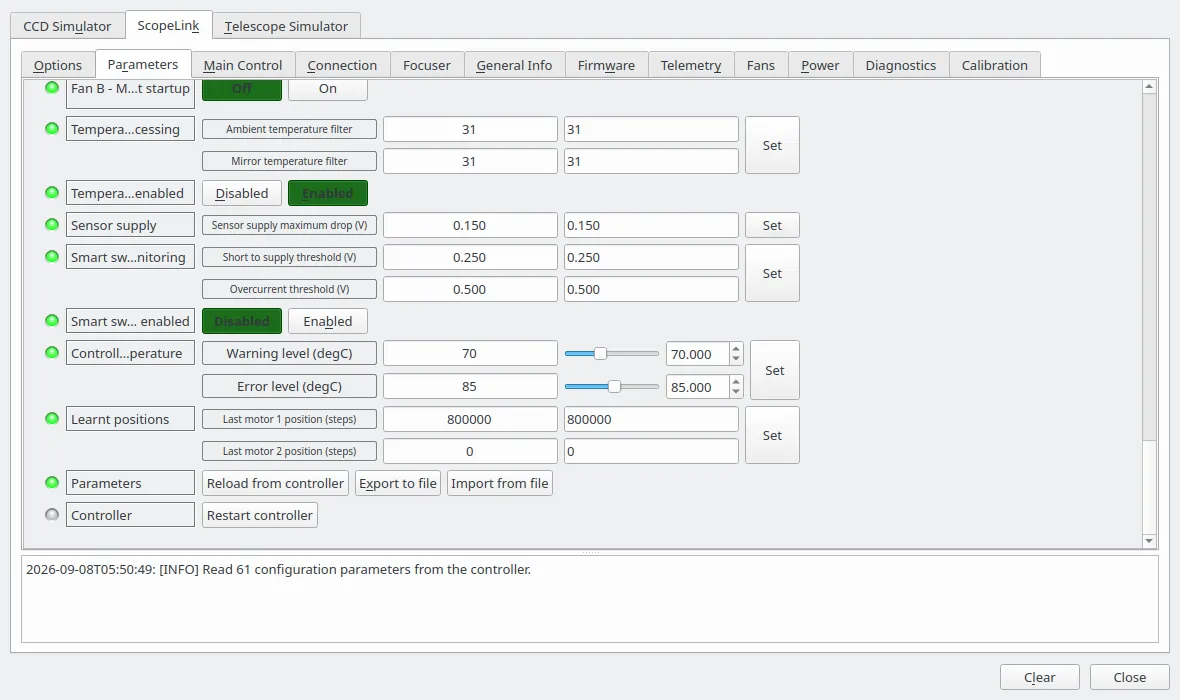
Section titled “Parameters”Every configuration value the connected controller holds, grouped the way the firmware groups them: one group per motor, then the focuser, the rotator and the front flap, each of the two fans, temperature processing, the sensor supply, smart switch monitoring, the controller’s own temperature, and the positions the unit has learnt. Values are read when the driver connects. Which groups appear depends on the unit — a value a controller does not hold is not offered, so a two motor controller has no Motor 3, and the Focuser, Rotator and Front flap groups appear only on a controller that holds the motor assignment.
The distinction between Motor 1 and Focuser is the one interface 1.1 introduced. A motor group is the motor itself — its currents, its acceleration, whether its direction is inverted — and belongs to the motor whatever it is driving. The Focuser, Rotator and Front flap groups are the job: which motor does it, and the few settings that belong to the job rather than to the hardware, such as the flap’s opening order and the delays between its parts. See “Which motor drives what”.
Values are shown in the units the firmware uses them in, so a velocity reads as 1.500 rev/s rather than
as the number the controller stores, and the limits on each field are the ones the controller will
actually accept. A value it would refuse is refused here, with a message saying what the range is, rather
than being sent and bounced.
A setting that is one of a fixed set of choices — a motor’s direction, a fan’s startup override, whether temperature processing is on, which motor drives what — is its own switch rather than a number, so it can be set by name:
indi_setprop 'ScopeLink.PARAM_MOTOR1_INVERT_DIRECTION.MOTOR_DIR_INVERTED=On'Only the values you actually change are written. This matters: they live in EEPROM, which has a finite number of write cycles, and the wear counters on the Diagnostics tab exist because of it. After a write the driver reads the value back, so anything the controller clamped or refused is visible immediately.
- Reload from controller — read every value again.
- Export to file — write the whole configuration to the path in Parameter file.
~/is expanded. - Import from file — read that file and write any values that differ to the controller.
The file format is the one the vendor’s Windows parameter editor reads and writes, so configurations move between the two platforms. A file exported from a generation 3 unit can be imported on a generation 2 one; values that generation does not hold are skipped.
Take an export before changing anything. It is the only backup of a unit’s calibration.
Diagnostics
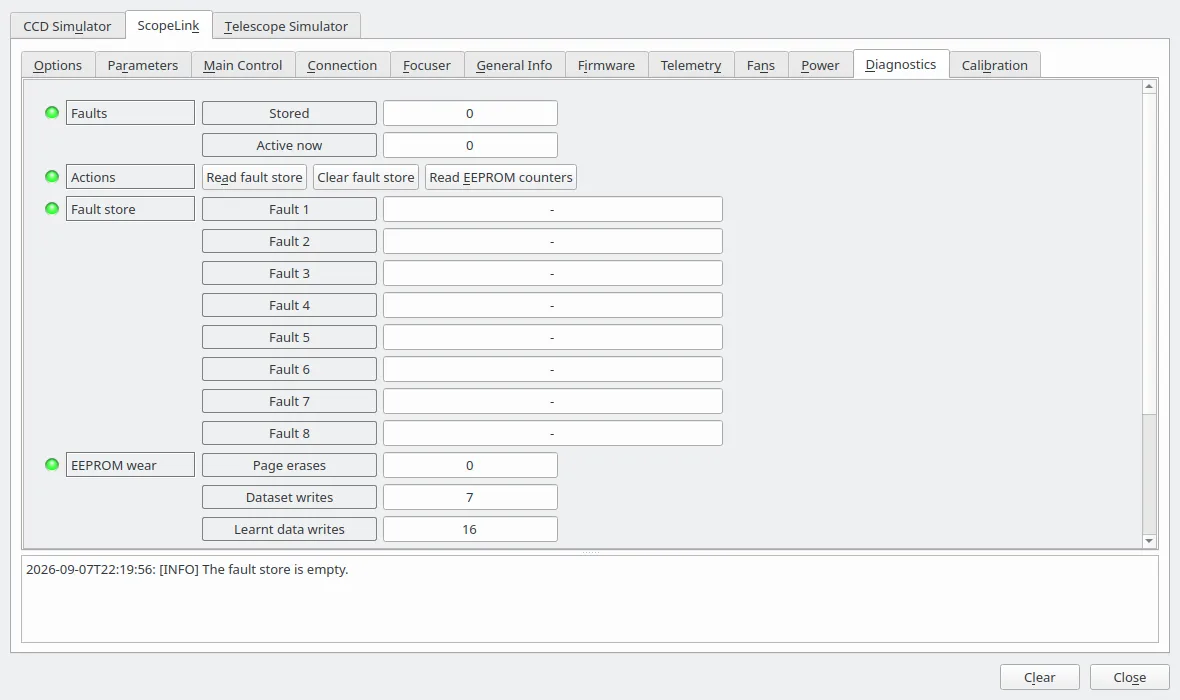
Section titled “Diagnostics”Faults shows how many diagnostic trouble codes are stored and how many are active right now.
- Read fault store — lists the stored codes with, for each, whether it is currently active, how many times it has been seen and when it was first recorded. The full freeze frame — around thirty values captured at the moment the fault was raised — is written to the driver log, where it can be copied into a support request.
- Clear fault store — clears every stored code and reads the store back. A code whose cause is still present reappears immediately, which is the point of reading it back.
- Read EEPROM counters — the wear counters for the controller’s configuration memory.
Link health shows the transaction, retry and failure counts for the serial link, and how old the most recent status sample is. Retries are normal on a busy USB bus; a rising failure count is not.
Calibration
Section titled “Calibration”Establishes a motor’s travel. Every motor the controller has is listed, labelled with what it currently drives — including one that drives nothing, because a motor has to be calibrated before it is worth assigning to anything. The procedure is the same for all of them:
- Select the motor.
- If the travel is unknown or wrong, press Reset calibration. The motor is then free to move anywhere, and believes it is in the middle of an unbounded travel.
- Jog the motor to one end stop, using Jog towards zero and Jog away from zero with a jog size that gets smaller as you approach. Watch the motor load while you do — a rising load means you have reached the stop.
- Press Mark as zero.
- Jog to the other end stop.
- Press Mark as end of travel.
Stop halts the selected motor immediately.
The travel readouts update as you go, and the driver picks up the new limit without a reconnect.
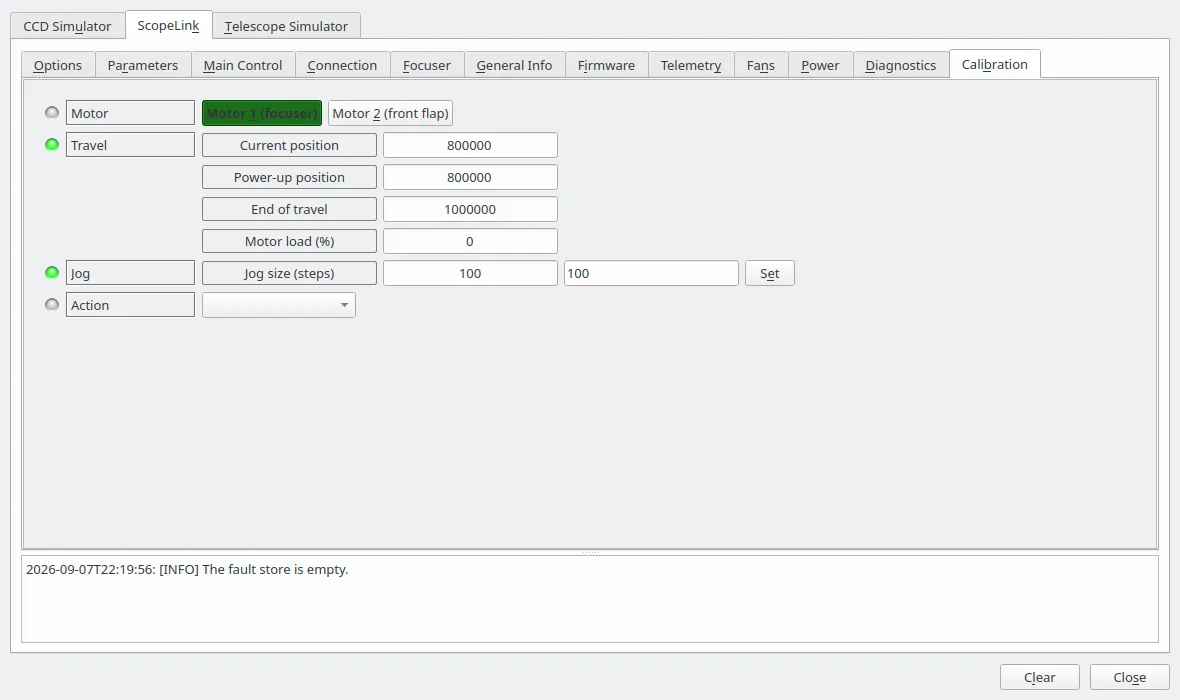
Take care with the front flap. Once it is calibrated, Ekos will drive it automatically. A flap whose travel is set wrong will be driven into its end stop on every sequence.
Calibration always addresses a motor rather than a job, on every controller: finding where a flap stands open means driving its motor before anything knows what its open position is. A controller from interface 1.1 refuses a motor command for a motor it is currently driving as part of a flap sequence, so stop the flap before calibrating one of its parts.
Firmware
Section titled “Firmware”Replaces the controller’s firmware with a file Astrolabs supplies.
Firmware is issued as one encrypted file per unit, named after that unit’s identifier — the Unit value on the General Info tab. A file named for anything else is refused before the controller is touched, because a file for one unit cannot be decrypted by another.
- Put the path of the file in Firmware file.
- Press Check the file.
- Press Install firmware, and leave the controller plugged in until it finishes.
The progress bar and the status line follow the update; the driver log records each step. The whole thing takes well under a minute.
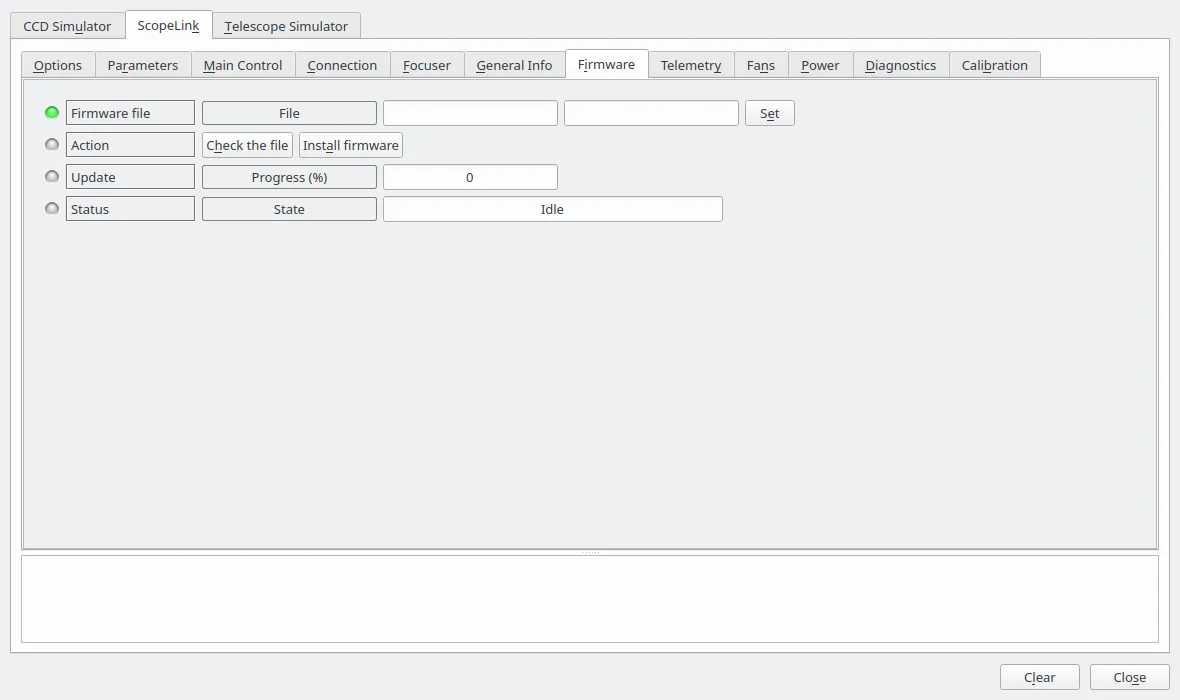
Nothing else has to be installed. The controller carries a boot loader of its own that appears as the same serial port the firmware does, so the update is an ordinary conversation on the port the driver is already connected to. There is no DFU mode to enter, no second device on the bus and nothing to run as root — and the driver never decrypts the file. It hands it over unopened, and the boot loader is what checks the contents as they arrive and then verifies what it programmed by reading the flash back.
Your configuration is expected to survive. Only the firmware area is erased, and the controller keeps
its parameters elsewhere. The driver still saves the whole configuration to ~/.indi/ before it starts,
and afterwards puts back anything the new firmware does not already have right — and tells you if it had
to. The file it saved is in the same format as Export to file on the Parameters tab, so it can be
restored by hand.
The update will not start while a motor is moving, and the device cannot be disconnected while one is running.
If an update is interrupted — the power goes, or the driver is stopped — the controller is left in its boot loader with no firmware to run. It is not bricked. Connect to it again: the driver will say that is what it found, and will offer the Firmware tab and nothing else. Install the firmware again from there, or run
scopelink-cli --port … flash <file>. The boot loader is in a part of the flash an update cannot write to, so it is always still there to try again through.
Firmware updates are not simulated: the one question worth asking of one is whether a real controller survives it.
Troubleshooting
Section titled “Troubleshooting”The port cannot be opened. Reload the udev rules with
sudo udevadm control --reload-rules && sudo udevadm trigger and unplug and replug the controller.
Failing that, add your user to the dialout group and log out and back in.
The port keeps changing number. /dev/ttyACMn is handed out in the order devices are plugged in.
Point the profile at /dev/scopelink, or at the /dev/serial/by-id/ name where there is more than one
controller, as described under Connecting; both stay with the unit.
“No ScopeLink answered on …”. Something is on the port but it is not answering as a ScopeLink. Check
you have the right port — scopelink-cli --port /dev/ttyACM0 info is a quicker way to test than a full
client — and that nothing else has the port open. The driver refuses the connection rather than
half-connecting to an unknown device.
“hardware generation N is not supported”. The controller is newer than the driver. Update the driver.
The driver disconnects itself during a session. Three failed status polls in a row are treated as a lost controller, after the protocol layer has already retried each one three times. Check the USB cable and the supply voltage on the Telemetry tab; a supply sagging under load is the usual cause. The Link health readout on the Diagnostics tab shows whether the link was struggling beforehand.
No temperature readings. Either the unit has no infrared sensor fitted — in which case the properties are not offered at all — or the sensor has stopped answering, in which case they go to alert and a fault is stored. Read the fault store to tell the two apart.
The flap state is reported as unknown. It stopped between its end stops, most likely because power was lost mid-travel. Close or open it once to re-establish where it is.
There is no focuser, no rotator or no dust cap where you expected one. On a controller that holds the motor assignment, a device is offered only when a motor is assigned to it and that motor has a calibrated travel. Look at the log line the driver prints on connect, which names the whole assignment; then set the assignment on the Parameters tab or calibrate the motor on the Calibration tab. A new assignment needs the controller restarted, which is what Restart controller on the Parameters tab does; a new calibration needs only a reconnection. Nothing about this changes while connected, deliberately — a client that has been handed a focuser cannot have a different one put underneath it.
“The controller’s motor assignment is unusable”. The controller is holding an assignment that breaks one of its own rules — a motor that is not fitted, a gap in the flap parts, or one motor claimed by two functions — and the message says which. No focuser, rotator or front flap is offered until it is corrected on the Parameters tab. A controller normally refuses such an assignment when it is written, so seeing this at all usually means the configuration came from a unit with more motors than this one.
A device you have just assigned a motor to refuses everything, with “no motor is assigned to it” even though the Parameters tab plainly says one is. The controller has not restarted since you changed it, so the assignment it is driving from is still the old one. Press Restart controller on the Parameters tab.
A move comes back refused. The controller checks a move against its own idea of the mechanism, and the driver reports what it said rather than a generic failure: no motor assigned, no calibration to move within, a position outside the travel, or the mechanism already moving and not taking a new target until it stops. The last of those is worth knowing during a flap sequence — a flap part waiting out its opening delay is still moving as far as the controller is concerned.
“This ScopeLink is sitting in its boot loader and has no firmware to run”. A firmware update did not finish. Nothing is broken and nothing has been lost: install the firmware again from the Firmware tab, which is the only tab offered in that state. See Firmware, above.
”… is not named after this ScopeLink”. Firmware files are encrypted for one unit and named after it. Either the file belongs to another controller, or it has been renamed — some browsers add a suffix to a downloaded file. Restore the name it was delivered with; the identifier it must match is the Unit value on the General Info tab.
“The transfer lost its place N bytes in”. A USB frame was dropped mid-update. The controller decrypts the file as it arrives and cannot be picked up again part way through, so the update has to start from the beginning — press Install firmware again. The controller is waiting in its boot loader and no firmware has been started, so nothing else needs doing.
Reporting problems
Section titled “Reporting problems”Include:
- the four values from the General Info tab
- the driver log with Debug enabled, covering the problem
- the freeze frames from Read fault store
- an export of the parameters