Wanderer ETA M54
Overview
Section titled “Overview”The Wanderer ETA M54 is an ultra-thin (5mm) electronic tilt adjuster with three independently motorized adjustment points. It mounts between optical train components using M54 threads and allows precise tilt correction with 0.001mm resolution over a 0–1.200mm range per point.
The INDI driver communicates via USB serial (CH340 chip, 19200 baud) and provides independent control of all three tilt adjustment motors with real-time encoder position feedback.
Features
Section titled “Features”- 3 independent motor position controls (0.000–1.200mm range, 0.001mm step)
- Real-time encoder position readback
- Zero All function to return all motors to home position
- Configuration save/restore (positions are remembered across sessions without triggering motor movement on reconnect)
- Position verification via continuous status stream polling
Connection
Section titled “Connection”Connect the Wanderer ETA M54 to a USB port. The device uses a CH340 USB-to-serial adapter.
- In the Connection tab, select the serial port (typically
/dev/ttyUSB0) - Baud rate is fixed at 19200 (configured automatically)
- Click Connect
The driver reads the device’s continuous status stream to verify the connection and displays the firmware version.
Main Control
Section titled “Main Control”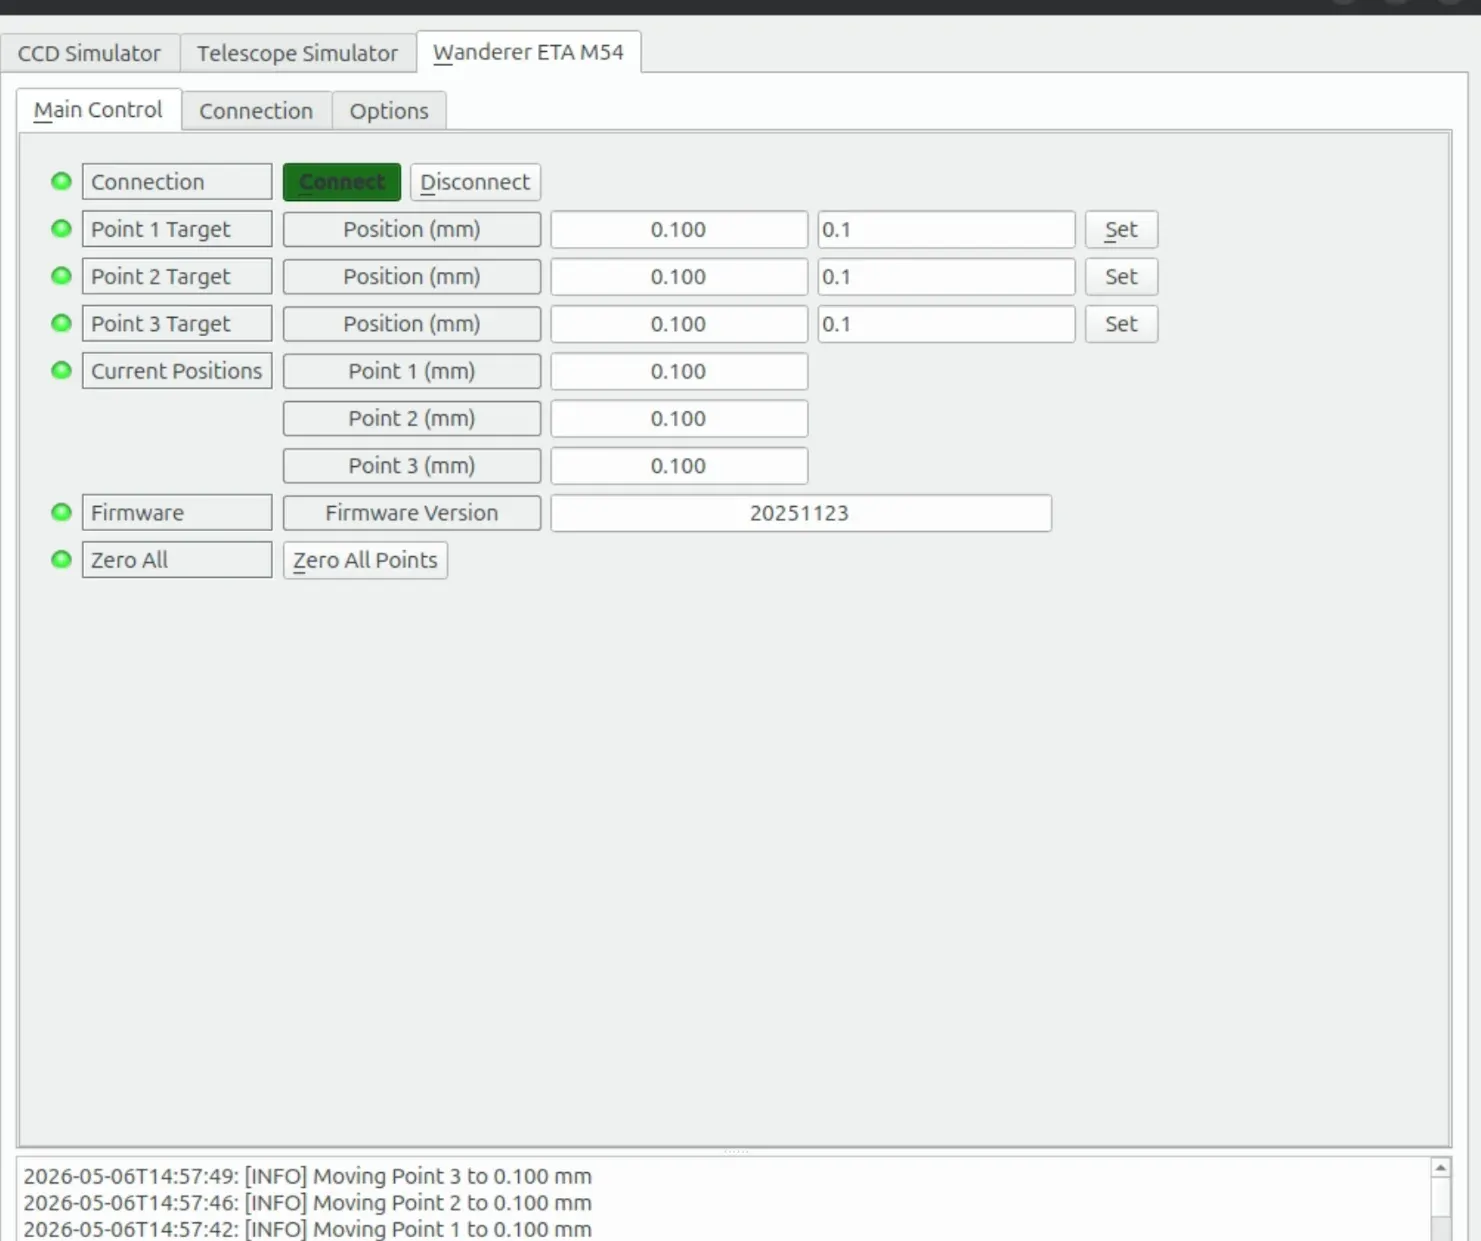
Target Positions
Section titled “Target Positions”Each motor point has its own target position property with an individual Set button:
- Point 1 Target — Set position for motor 1 (0.000–1.200mm)
- Point 2 Target — Set position for motor 2 (0.000–1.200mm)
- Point 3 Target — Set position for motor 3 (0.000–1.200mm)
Each motor moves independently. Setting one point does not affect the others.
Current Positions
Section titled “Current Positions”The Current Positions group shows real-time encoder readback from all three motors. These values update automatically every 2 seconds and reflect the actual physical position of each adjustment point.
Zero All
Section titled “Zero All”The Zero All Points button moves all three motors to the 0.000mm position sequentially. Use this to return the device to a flat (no tilt) state.
Firmware
Section titled “Firmware”Displays the firmware version reported by the device.
Operation
Section titled “Operation”Adjusting Tilt
Section titled “Adjusting Tilt”- Connect to the device
- Set the desired position for one or more points using the individual target fields
- Click Set next to the point you want to move
- The motor moves to the target position; readback updates in real-time
- Repeat for other points as needed
The driver waits for each motor to reach its target (within ±0.005mm tolerance) before reporting completion.
Saving Configuration
Section titled “Saving Configuration”To preserve your tilt settings across sessions:
- Set all points to the desired positions
- Go to Options → Save Configuration
On the next connection, the saved positions are restored as targets without triggering any motor movement. Motors only move when you explicitly click Set or Zero All.
IMPORTANT
The device does not have absolute position memory across power cycles. When powered on, the motors report their physical position from the encoders. The saved INDI configuration stores your last-used target values for convenience.
Troubleshooting
Section titled “Troubleshooting”| Symptom | Cause | Solution |
|---|---|---|
| Timeout reading from device | ETA not powered or wrong port | Check USB connection, verify port in dmesg |
| Unknown device identifier | Wrong WandererAstro device on port | Ensure the ETA (not rotator/cover) is selected |
| Motor does not reach target | Mechanical obstruction | Check optical train for binding; reduce target value |
Hardware Specifications
Section titled “Hardware Specifications”| Parameter | Value |
|---|---|
| Interface | USB (CH340 serial adapter) |
| Baud Rate | 19200 |
| Thread | M54 × 0.75 |
| Thickness | 5mm |
| Travel Range | 0–1.200mm per point |
| Resolution | 0.001mm |
| Adjustment Points | 3 (120° spacing) |
| Power | USB bus powered |